Project file 03 / Krishna Defence
Finding position without GPS.
Contribution by
Kartikey Pathak & Vishal Mutha
These are contributions by our team members in earlier or ongoing roles at other companies. They are not projects commissioned from Kaspevo Labs.
The need
Explore localisation for places where GPS is unavailable.
Our team’s part
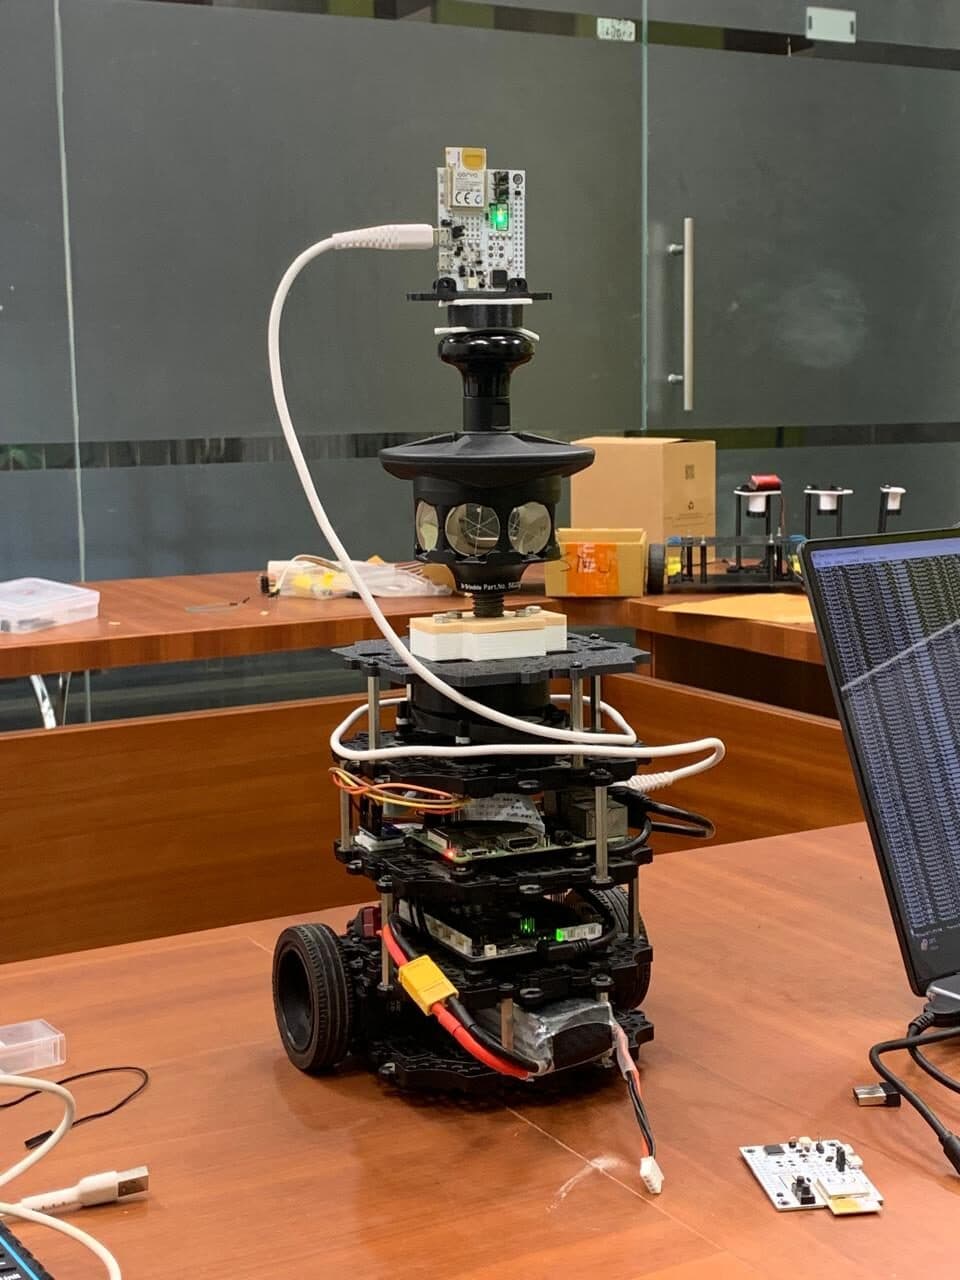
A localisation proof of concept using ultra-wideband (UWB).
The outcome
An early system to explore positioning for GPS-denied environments.
A closer look
What went
into the work.
Kartikey and Vishal worked on a UWB localisation proof of concept. The intended use included GPS-denied and naval settings, where another way to estimate position is needed.
A proof of concept helps test whether a technical approach is worth taking further.
The work in four steps
- 01
Understand the positioning problem
- 02
Explore UWB localisation
- 03
Bring up the hardware and software
- 04
Evaluate the proof of concept
The work described here is a proof of concept, not a claim of naval deployment or a production-ready defence system.
Good ideas deserve a first build.
What do you want to build?
Bring the problem. Let’s work out the next step together.