Project file 01 / NishCorp Technologies
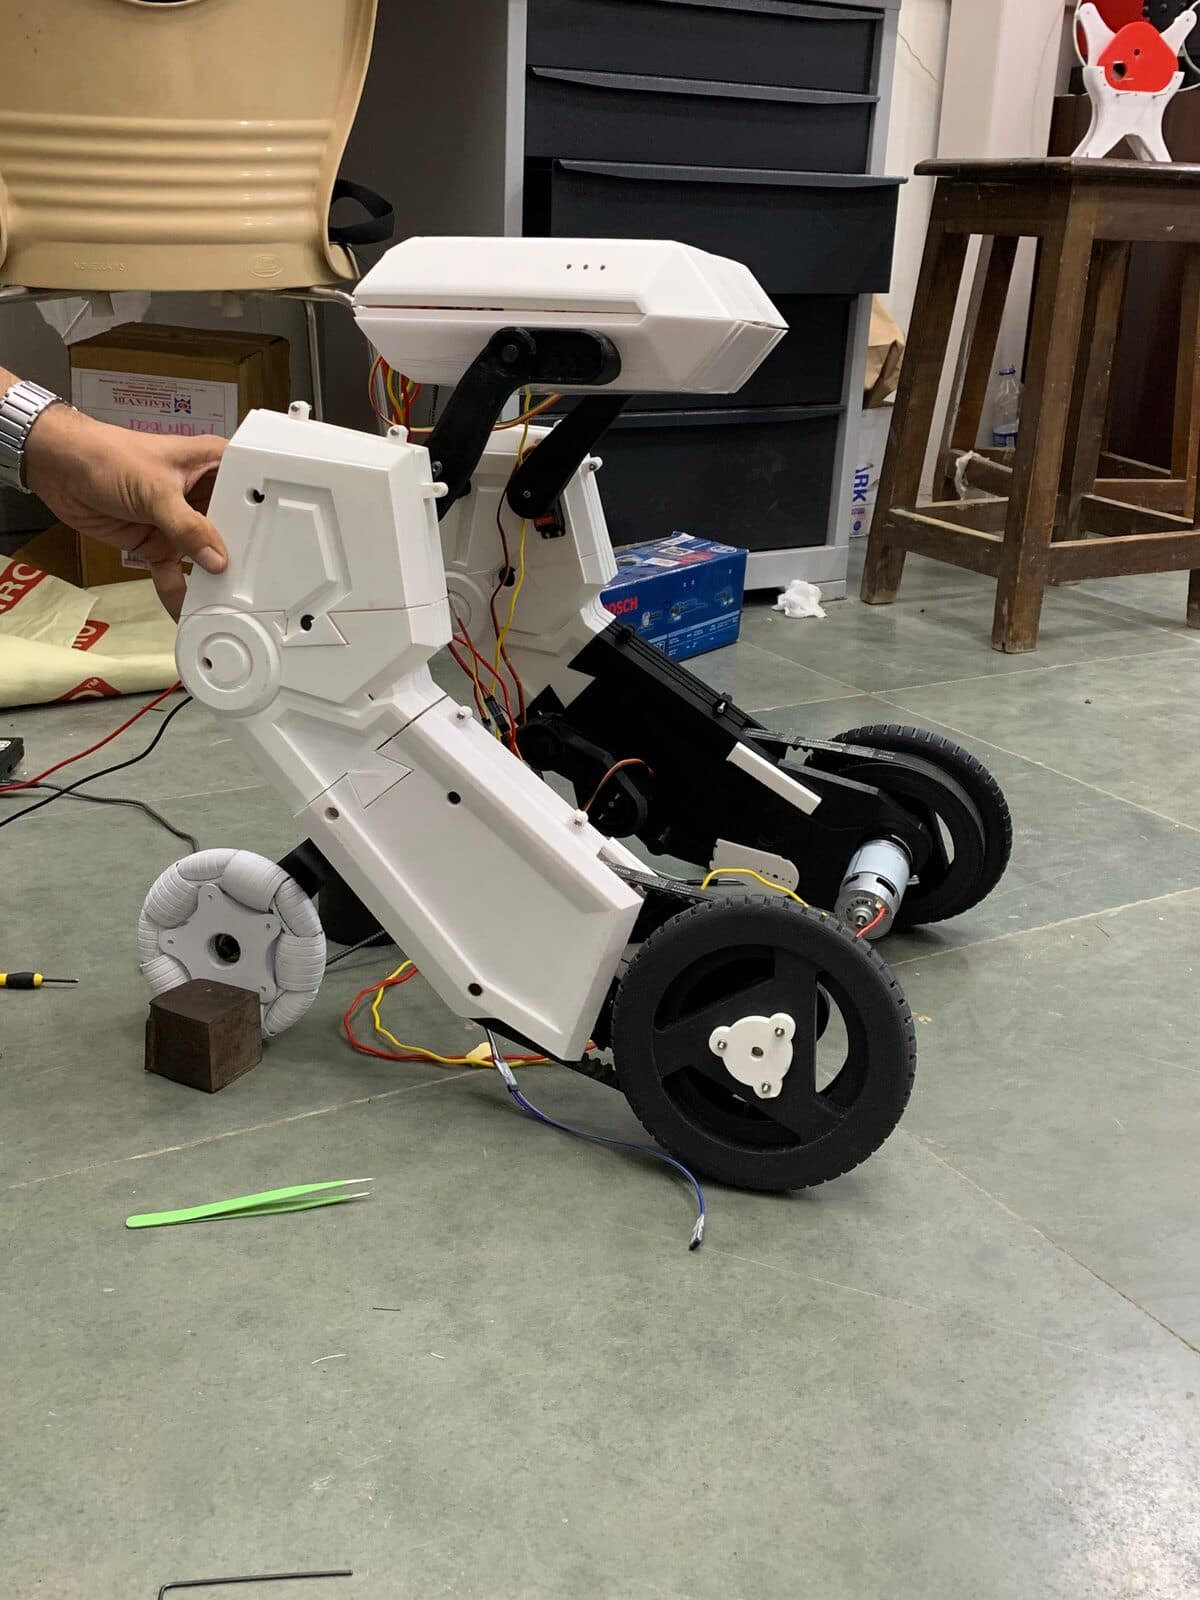
A first step for a stair-climbing wheelchair.
Contribution by
Kartikey Pathak
These are contributions by our team members in earlier or ongoing roles at other companies. They are not projects commissioned from Kaspevo Labs.
The need
Build the first prototype of a stair-climbing wheelchair.
Our team’s part
ROS software and hardware bring-up using a perfboard build.
The outcome
Software and physical hardware brought together for an early prototype.
A closer look
What went
into the work.
Kartikey helped develop the ROS stack and bring up the actual hardware. A perfboard build made it possible to start connecting and testing the system before a custom PCB.
The value of this stage was putting the idea into physical hardware that the company could develop further.
The work in four steps
- 01
Define the first prototype
- 02
Develop the ROS stack
- 03
Bring up the perfboard hardware
- 04
Connect software and physical systems
This was an early prototype. This story does not claim a finished, certified mobility product.
Good ideas deserve a first build.
What do you want to build?
Bring the problem. Let’s work out the next step together.